Feedback → Concept → Plan → ActionExplore
IEEE Transactions on Robotics 2026
Unifying Deep Predicate Invention with Pre-trained Foundation Models
* Equal contribution
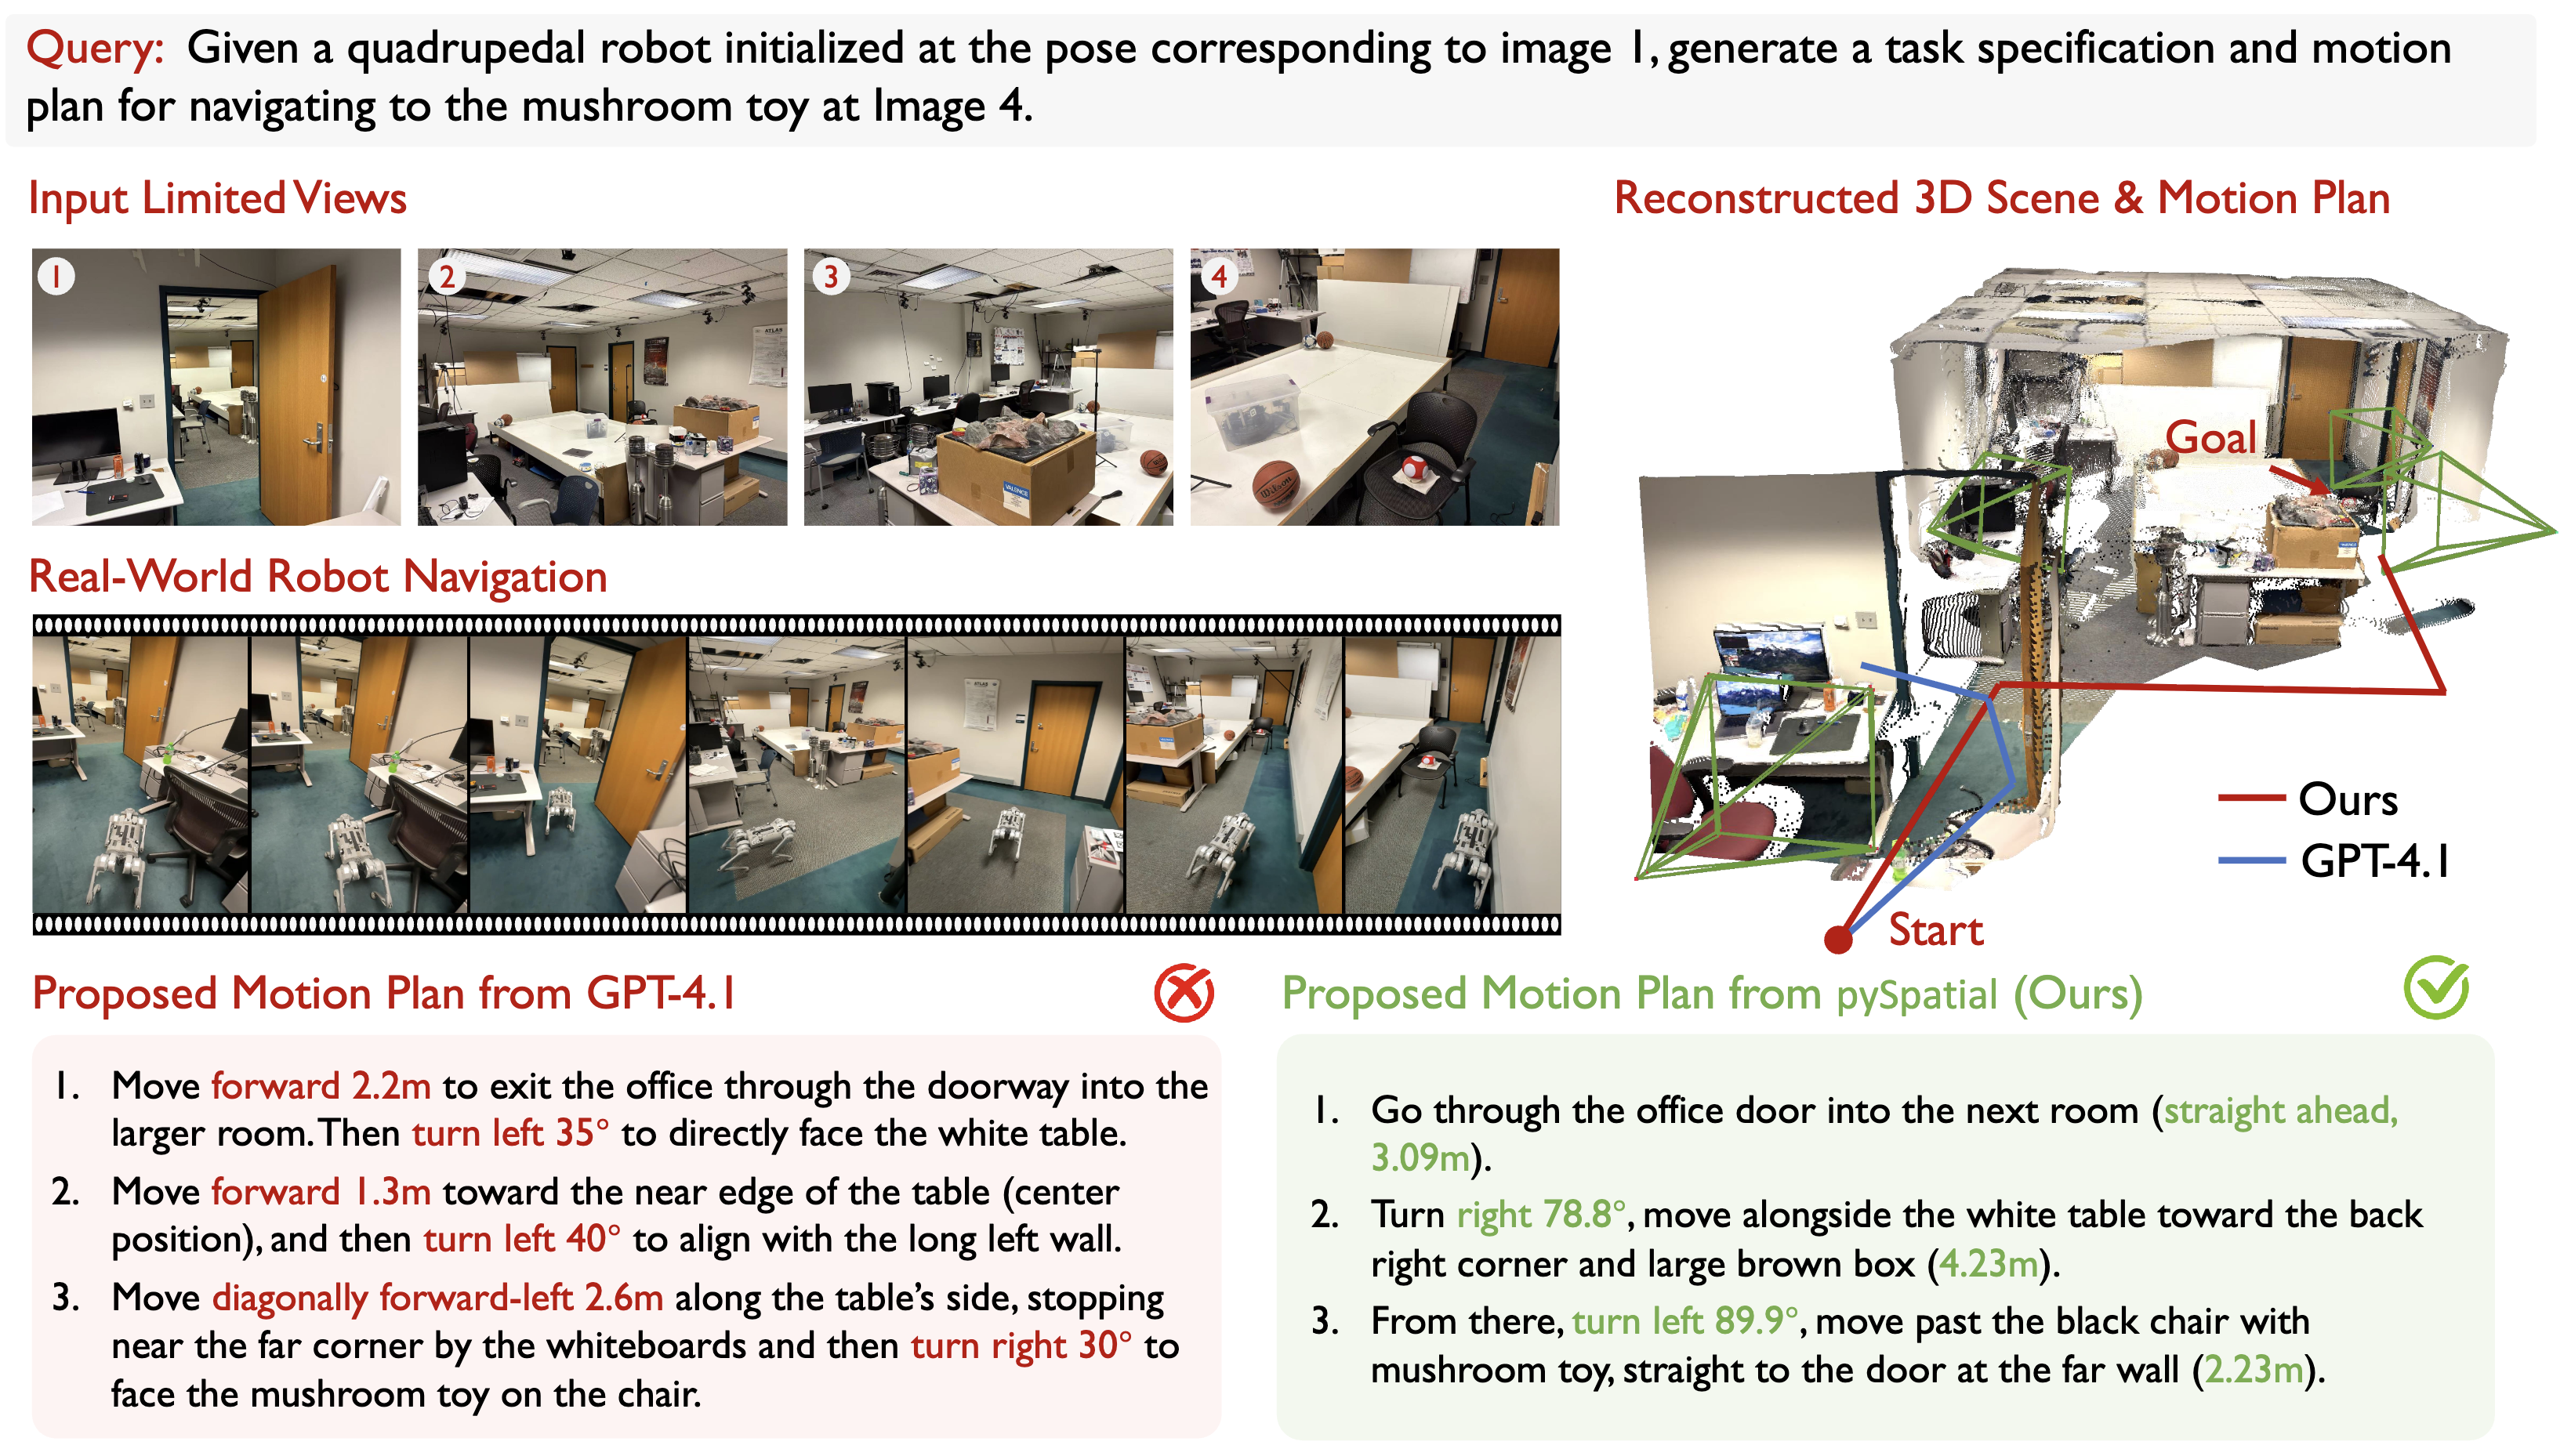
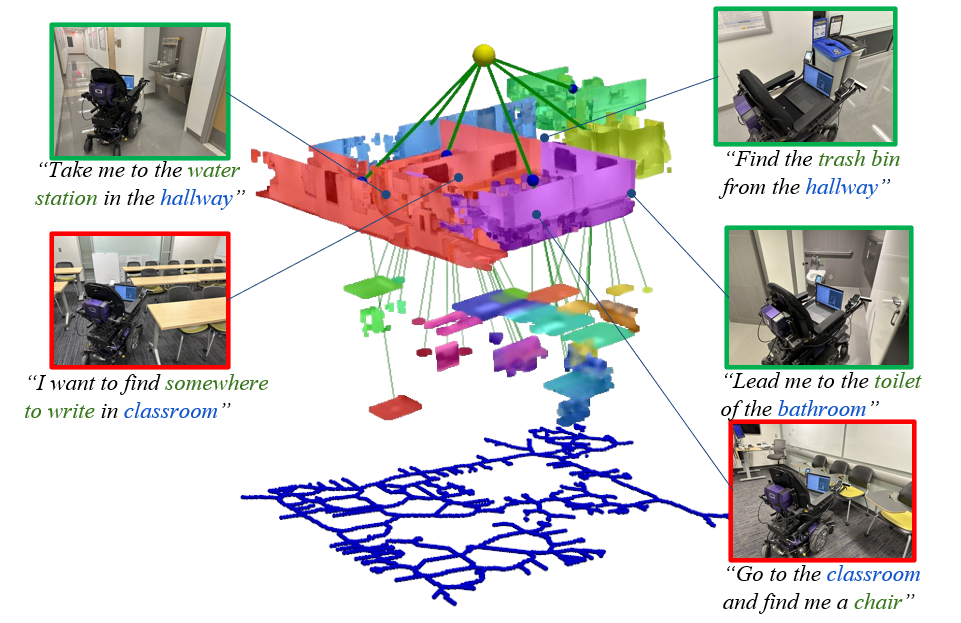
UniPred learns concepts from human demonstrations with an agent in the loop, connecting perceptual learning to long-horizon robot planning.